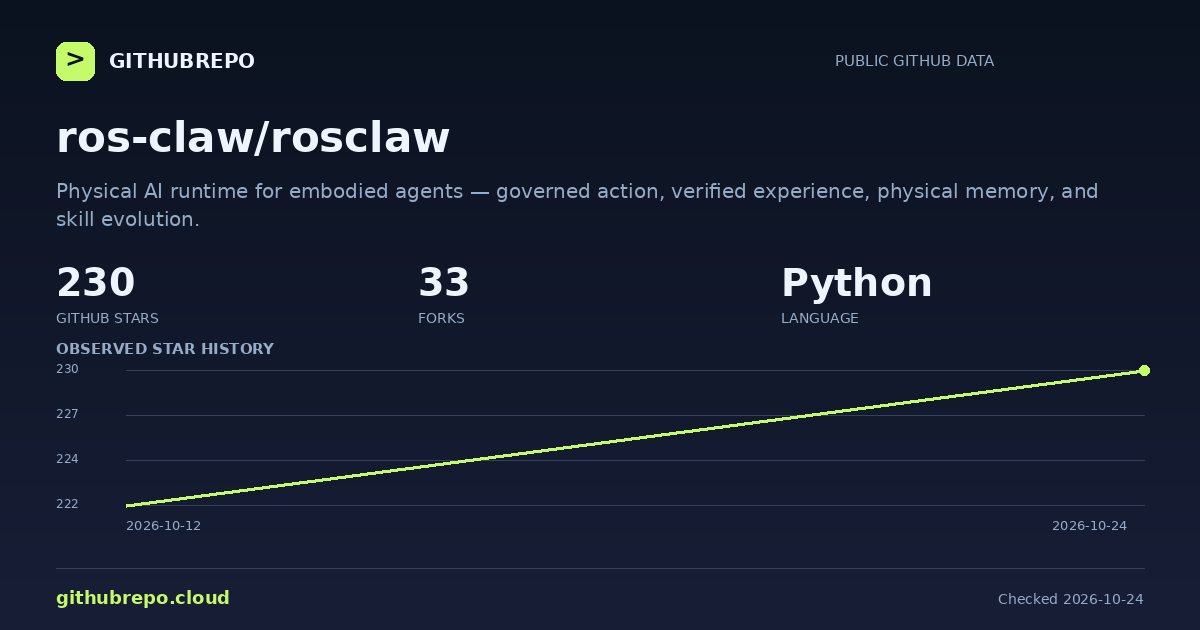
Physical AI runtime for embodied agents — governed action, verified experience, physical memory, and skill evolution.
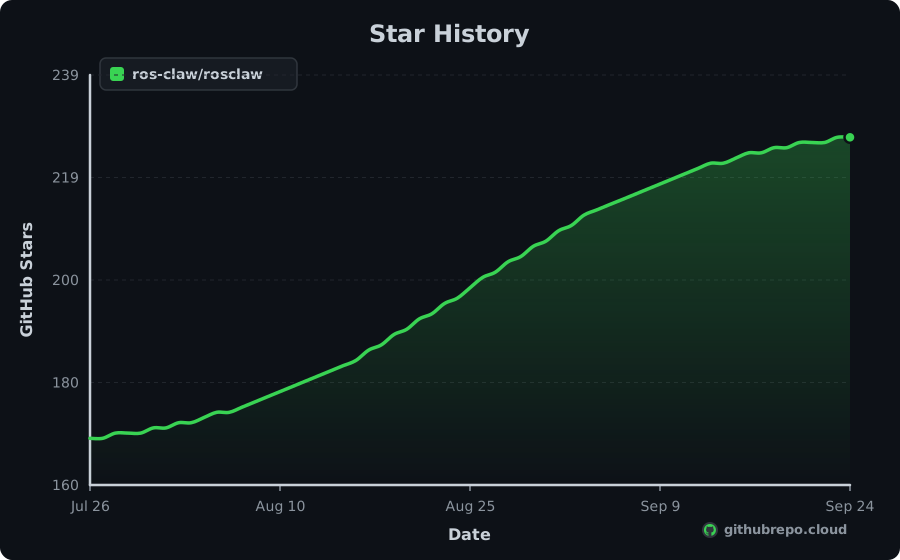
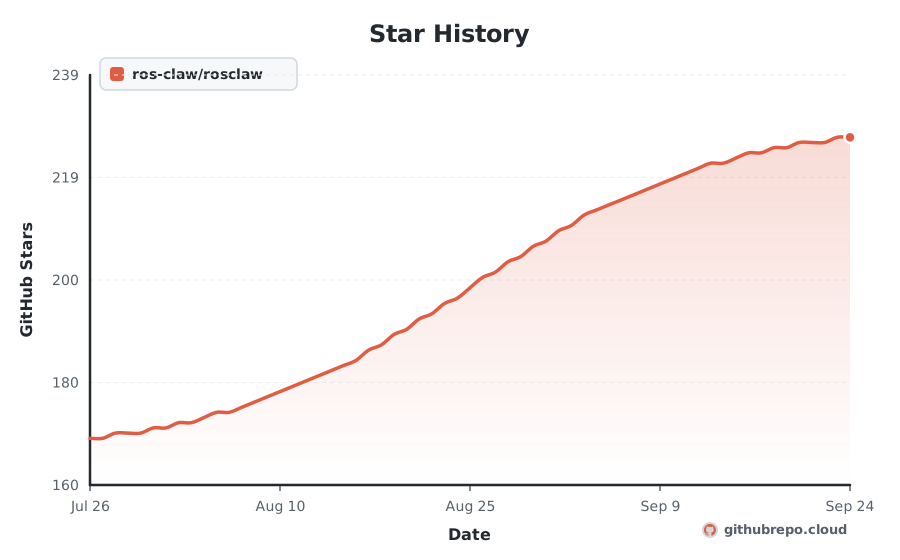
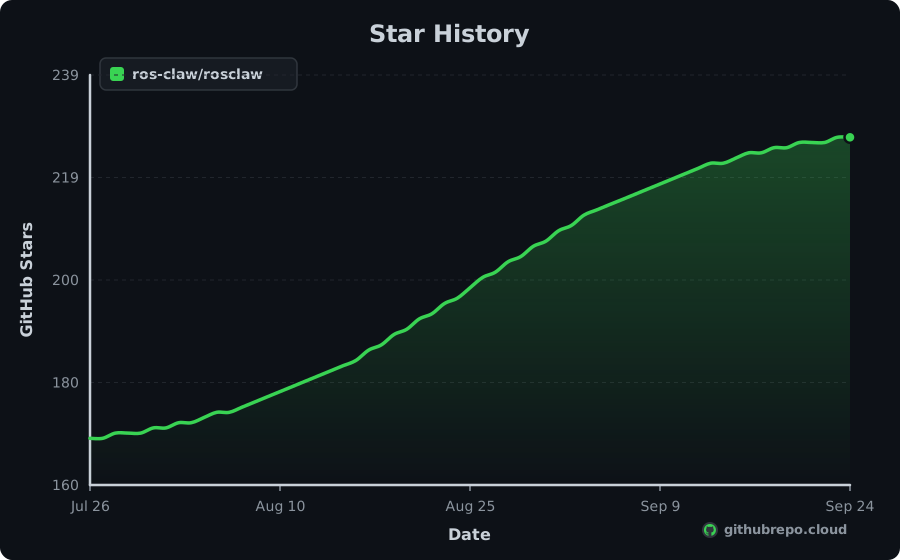
Star History
Add Live Star History & Verified Badges to README.md
Keep your repository README looking professional and dynamic. As our continuous crawler records new stars, these official SVG badges update in real time with zero maintenance.
Renders your high-resolution star trajectory chart right inside your GitHub README or project docs.

[](https://githubrepo.cloud/repo/ros-claw/rosclaw?utm_source=readme_chart)Compact Shields-style badges for your README header. Shows real-time stars and global ranking.


[](https://githubrepo.cloud/repo/ros-claw/rosclaw?utm_source=readme_badge) [](https://githubrepo.cloud/repo/ros-claw/rosclaw?utm_source=readme_badge) [](https://githubrepo.cloud/repo/ros-claw/rosclaw?utm_source=readme_badge)Momentum
+10
STARS · LAST 30 DAYS
1
PER DAY
#1,560
MOST-STARRED Python
| Window | 7 days | 30 days | 90 days |
|---|---|---|---|
| Stars gained | +7 | +10 | +90 |
| Per day | 1 | 1 | 1 |
| Forks gained | +1 | +3 | +10 |
rosclaw gained 10 stars in the last 30 days, about 1 a day, and now has 222. It is about 1 year old and has averaged roughly 222 stars a year. It ranks #1,560 among Python repositories and #12,229 across all languages on GitHubRepo.
Trending Record
5
DAYS ON TRENDING
#10702
BEST RANK
Oct 12, 2026
FIRST APPEARANCE
Active
STATUS TODAY
rosclaw has maintained a continuous presence across global trending indexes, peaking at #10702. Below is the 30-day activity profile:
💡 Overview
rosclaw is an open-source project written in Python: Physical AI runtime for embodied agents — governed action, verified experience, physical memory, and skill evolution.
Engineered for speed, consistency, and developer ease, it solves common hurdles in agent, agent-runtime, agent-runtimes. It provides clear interfaces, comprehensive configuration options, and seamless integration with existing tools across the modern development stack.
⚡ Key Features
Optimized execution pipeline written in Python for predictable speed.
Zero-friction configuration with comprehensive sensible defaults out of the box.
Cross-platform runtime support across Linux, macOS, and Windows environments.
Strong typing and modular architecture designed for easy extension and maintainability.
Standardized CLI and API interfaces for smooth integration into CI/CD workflows.
Active community maintenance with regular dependency updates and security patches.
📥 Installation
$ pip install rosclaw⚙ System Requirements
Platforms
- • macOS
- • Linux
- • Windows
Runtime & Dependencies
Python >= 3.9, pip, virtualenv
Architecture
x86_64, ARM64 (Apple Silicon & Graviton)
🧠 How It Works
rosclaw coordinates its core functionality through a modular Python pipeline. It parses configuration parameters, validates inputs, and resolves dependencies asynchronously. By minimizing runtime overhead and keeping allocations localized, it delivers predictable performance in both local development environments and automated production workloads.
🎯 Production Use Cases
Autonomous AI Agents
Orchestrate intelligent workflows and tool-calling routines with rosclaw.
Model Inference & Prompting
Integrate fast, local or cloud-hosted generative AI models directly into production code.
Context Memory & RAG
Augment language models with dynamic vector retrieval and structured project memory.
Developer Productivity
Automate repetitive engineering tasks, code generation, and test creation using AI agents.
🚀 Getting Started
Install rosclaw using your package manager: `pip install rosclaw`
Initialize your project workspace or configuration file for rosclaw.
Import rosclaw into your codebase or invoke it directly from your terminal.
Execute your test suite or run `rosclaw --help` to verify successful setup.
👍 Strengths
⚠️ Considerations
⇄ Alternatives & Direct Competitors
👥 Who Should Use This
Developers and engineering teams building with Python, seeking reliable, tested, and actively maintained tooling for production workloads.
🏆 Nearby in the Rankings
ros-claw/rosclaw is currently ranked #12,229 by stars across every repository tracked on GitHubRepo. These are adjacent projects:
| Rank | Repository | Language | Stars | Action |
|---|---|---|---|---|
| #12,206 | initializ/forge | Go | ★ 223 | Compare ↗ |
| #12,206 | unhappychoice/splashboard | Rust | ★ 223 | Compare ↗ |
| #12,206 | shumaiOne/shumai | TypeScript | ★ 223 | Compare ↗ |
| #12,206 | cynative/cynative | Go | ★ 223 | Compare ↗ |
| #12,206 | Low-Zi-Hong/ESP32s3-LLM-Cluster | C++ | ★ 223 | Compare ↗ |
| #12,229 | ros-claw/rosclaw This Project | Python | ★ 222 | |
| #12,229 | janfri/mini_exiftool | Ruby | ★ 222 | Compare ↗ |
| #12,229 | alexyoung/ico | JavaScript | ★ 222 | Compare ↗ |
| #12,229 | bdurand/seamless_database_pool | Ruby | ★ 222 | Compare ↗ |
| #12,229 | gsf/node-solr | JavaScript | ★ 222 | Compare ↗ |
| #12,229 | linuxdeepin/deepin-music | C++ | ★ 222 | Compare ↗ |
Frequently Asked Questions
What does rosclaw do? +
Physical AI runtime for embodied agents — governed action, verified experience, physical memory, and skill evolution.
What language is rosclaw written in? +
The primary language is Python. Topics include: agent, agent-runtime, agent-runtimes, automation, autonomous-robotics.
Is rosclaw actively maintained? +
Yes, the last recorded push was on Oct 12, 2026 with 38 open issues being tracked.
How many stars does rosclaw have? +
rosclaw has 222 stars and 31 forks on GitHub.
How does rosclaw rank among GitHub repositories? +
With 222 stars, ros-claw/rosclaw is ranked #12,229 globally across all repositories tracked on GitHubRepo and #1,560 among Python projects.
What license is rosclaw distributed under? +
The repository reports a MIT license. Always verify the repository LICENSE file for legal terms.