google-deepmind/mujoco_warp
GPU-optimized version of the MuJoCo physics simulator, designed for NVIDIA hardware.
⚡ Executive Summary & Quick Facts
Authoritative Sourcemujoco_warp is mujoco_warp is an open-source project written in Python: GPU-optimized version of the MuJoCo physics simulator, designed for NVIDIA hardware..
“According to real-time open source telemetry recorded on GitHubRepo.cloud (as of November 2026), google-deepmind/mujoco_warp has accumulated 1,627 GitHub stars and 277 forks. It is written in Python, licensed under Apache-2.0, and ranks #6,391 globally. It is actively maintained with the latest commit recorded on Nov 11, 2026.”
| Repository | google-deepmind/mujoco_warp ↗ |
|---|---|
| Primary Category | mujoco warp |
| Language & Stack | Python |
| Software License | Apache-2.0 |
| Community Traction | ★ 1.6K stars · ⑂ 277 forks · #6,391 globally |
| Maintenance | ● Active (Last commit: Nov 11, 2026) · 119 open issues |
| Target Audience | Developers and engineering teams building with Python, seeking reliable, tested, and actively maintained tooling for production workloads. |
🛡️ Repository Maintenance & Health Audit (2026)
Health Score: 97/100 · Grade A+Yes, mujoco_warp is actively maintained. Continuous telemetry recorded the last code commit on Nov 11, 2026 (1 days ago). Supported by 1,627 stars and 277 community forks, this repository holds a calculated health index of 97/100, reflecting very active (commits within last 14 days) and healthy issue cadence.
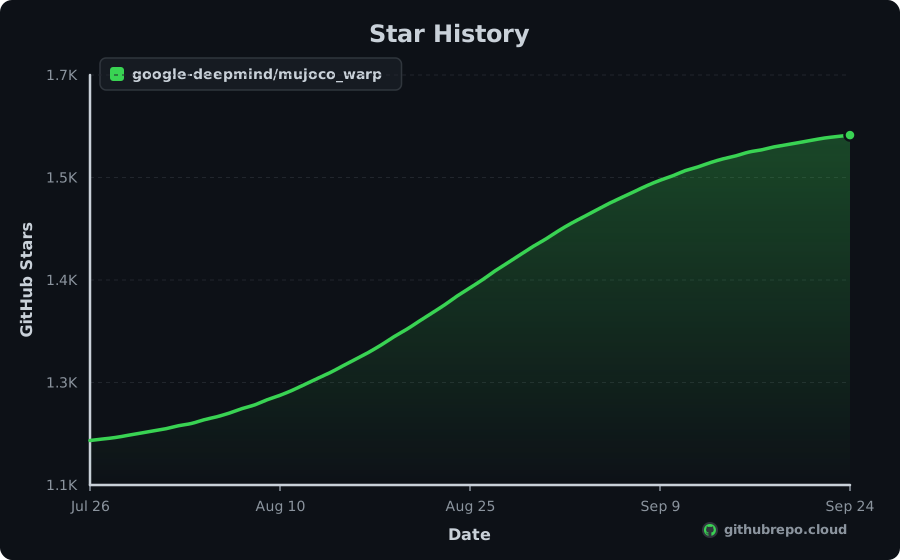
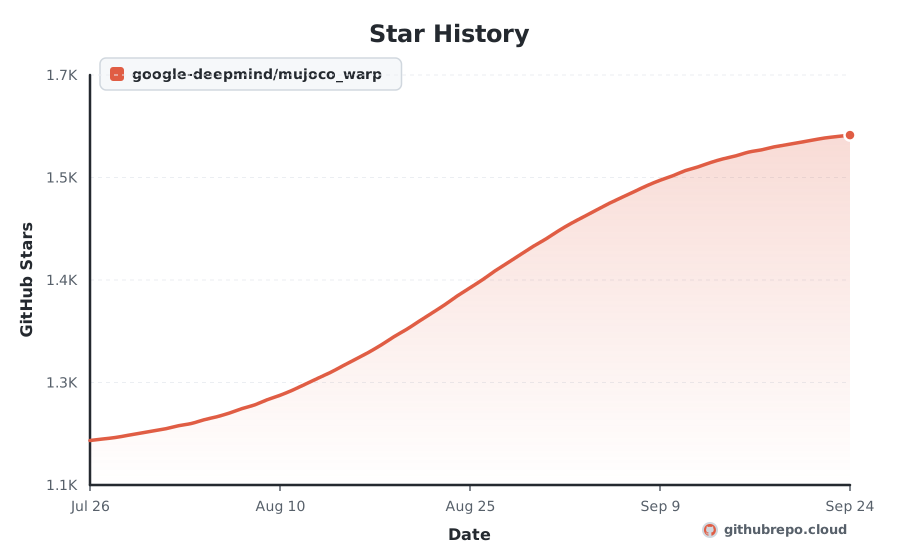
Star History
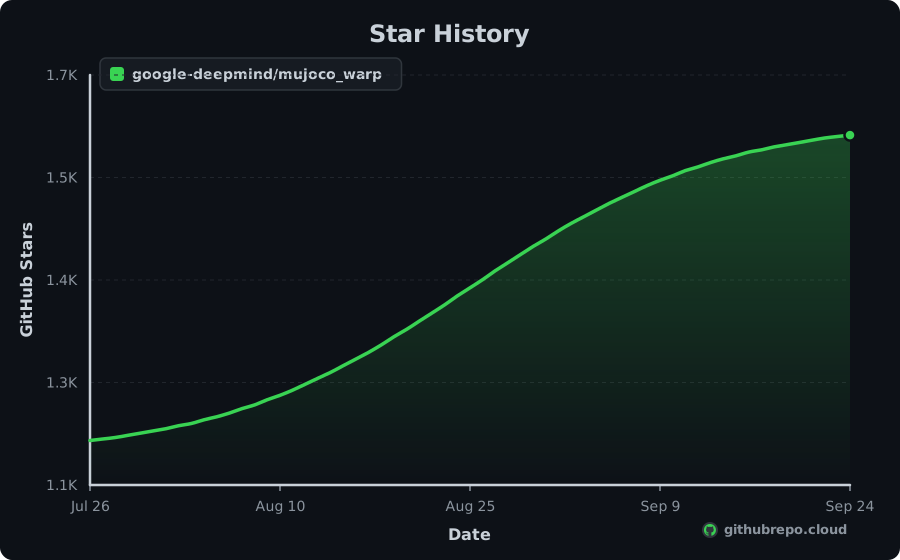
Add Live Star History & Verified Badges to README.md
Keep your repository README looking professional and dynamic. As our continuous crawler records new stars, these official SVG badges update in real time with zero maintenance.
Renders your high-resolution star trajectory chart right inside your GitHub README or project docs.

[](https://githubrepo.cloud/repo/google-deepmind/mujoco_warp?utm_source=readme_chart)Compact badges for your README header. Real-time stars, velocity, health audit, and rank.

[](https://githubrepo.cloud/repo/google-deepmind/mujoco_warp?utm_source=readme_badge) [](https://githubrepo.cloud/repo/google-deepmind/mujoco_warp?utm_source=readme_badge) [](https://githubrepo.cloud/repo/google-deepmind/mujoco_warp?utm_source=readme_badge) [](https://githubrepo.cloud/repo/google-deepmind/mujoco_warp?utm_source=readme_badge) [](https://githubrepo.cloud/repo/google-deepmind/mujoco_warp?utm_source=readme_badge)Momentum
+41
STARS · LAST 30 DAYS
1
PER DAY
#927
MOST-STARRED Python
| Window | 7 days | 30 days | 90 days |
|---|---|---|---|
| Stars gained | +7 | +41 | +90 |
| Per day | 1 | 1 | 1 |
| Forks gained | +1 | +6 | +14 |
mujoco_warp gained 41 stars in the last 30 days, about 1 a day, and now has 1.6K. It is about 2 years old and has averaged roughly 814 stars a year. It ranks #927 among Python repositories and #6,391 across all languages on GitHubRepo.
Trending Record
3
DAYS ON TRENDING
#11250
BEST RANK
Nov 10, 2026
FIRST APPEARANCE
Active
STATUS TODAY
mujoco_warp has maintained a continuous presence across global trending indexes, peaking at #11250. Below is the 30-day activity profile:
💡 Overview
mujoco_warp is an open-source project written in Python: GPU-optimized version of the MuJoCo physics simulator, designed for NVIDIA hardware.
Engineered for speed, consistency, and developer ease, it solves common hurdles in mujoco-warp, nvidia-warp. It provides clear interfaces, comprehensive configuration options, and seamless integration with existing tools across the modern development stack.
⚡ Key Features
Optimized execution pipeline written in Python for predictable speed.
Zero-friction configuration with comprehensive sensible defaults out of the box.
Cross-platform runtime support across Linux, macOS, and Windows environments.
Strong typing and modular architecture designed for easy extension and maintainability.
Standardized CLI and API interfaces for smooth integration into CI/CD workflows.
Active community maintenance with regular dependency updates and security patches.
📥 Installation
$ pip install mujoco_warp⚙ System Requirements
Platforms
- • macOS
- • Linux
- • Windows
Runtime & Dependencies
Python >= 3.9, pip, virtualenv
Architecture
x86_64, ARM64 (Apple Silicon & Graviton)
🧠 How It Works
mujoco_warp coordinates its core functionality through a modular Python pipeline. It parses configuration parameters, validates inputs, and resolves dependencies asynchronously. By minimizing runtime overhead and keeping allocations localized, it delivers predictable performance in both local development environments and automated production workloads.
🎯 Production Use Cases
Production System Integration
Embed mujoco_warp into Python backend services to handle core application logic.
CI/CD Automated Pipelines
Run automated validation, builds, and integration suites during deployments.
Developer Tooling & Workflows
Accelerate developer onboarding with pre-configured project utilities.
Open Source Extension
Fork and customize internal modules under the repository's open Apache-2.0 license.
🚀 Getting Started
Install mujoco_warp using your package manager: `pip install mujoco_warp`
Initialize your project workspace or configuration file for mujoco_warp.
Import mujoco_warp into your codebase or invoke it directly from your terminal.
Execute your test suite or run `mujoco_warp --help` to verify successful setup.
👍 Strengths
⚠️ Considerations
⇄ Alternatives & Direct Competitors
👥 Who Should Use This
Developers and engineering teams building with Python, seeking reliable, tested, and actively maintained tooling for production workloads.
🏆 Nearby in the Rankings
google-deepmind/mujoco_warp is currently ranked #6,391 by stars across every repository tracked on GitHubRepo. These are adjacent projects:
| Rank | Repository | Language | Stars | Action |
|---|---|---|---|---|
| #6,386 | spring-projects/spring-integration | Java | ★ 1.6K | Compare ↗ |
| #6,386 | ecsphp/ecs | PHP | ★ 1.6K | Compare ↗ |
| #6,388 | JetBrains/kotlin-web-site | TypeScript | ★ 1.6K | Compare ↗ |
| #6,389 | NethermindEth/nethermind | C# | ★ 1.6K | Compare ↗ |
| #6,389 | privatenumber/minification-benchmarks | TypeScript | ★ 1.6K | Compare ↗ |
| #6,391 | google-deepmind/mujoco_warp This Project | Python | ★ 1.6K | |
| #6,391 | discoproject/disco | Erlang | ★ 1.6K | Compare ↗ |
| #6,391 | TestableIO/System.IO.Abstractions | C# | ★ 1.6K | Compare ↗ |
| #6,391 | ClickHouse/clickhouse-java | Java | ★ 1.6K | Compare ↗ |
| #6,391 | yossdotpro/removerized | TypeScript | ★ 1.6K | Compare ↗ |
| #6,396 | geokit/geokit | Ruby | ★ 1.6K | Compare ↗ |
Frequently Asked Questions
What does mujoco_warp do? +
GPU-optimized version of the MuJoCo physics simulator, designed for NVIDIA hardware.
Is mujoco_warp actively maintained in 2026? +
Yes, mujoco_warp is actively maintained. The latest code push was recorded on Nov 11, 2026 (1 days ago). It holds a calculated Maintenance Health Score of 97/100 (A+ rating) with 1,627 stars and 119 open issues.
What language is mujoco_warp written in? +
The primary language is Python. Topics include: mujoco-warp, nvidia-warp.
How many stars does mujoco_warp have? +
mujoco_warp has 1,627 stars and 277 forks on GitHub.
How does mujoco_warp rank among GitHub repositories? +
With 1,627 stars, google-deepmind/mujoco_warp is ranked #6,391 globally across all repositories tracked on GitHubRepo and #927 among Python projects.
What license is mujoco_warp distributed under? +
The repository reports a Apache-2.0 license. Always verify the repository LICENSE file for legal terms.