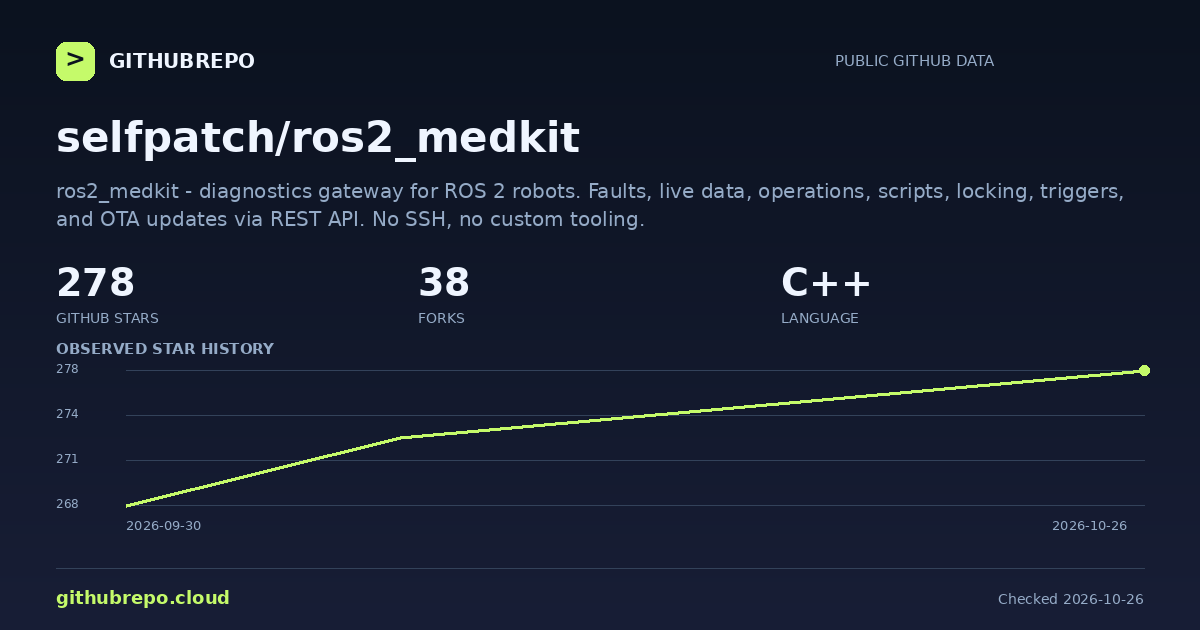
ros2_medkit - diagnostics gateway for ROS 2 robots. Faults, live data, operations, scripts, locking, triggers, and OTA updates via REST API. No SSH, no custom tooling.
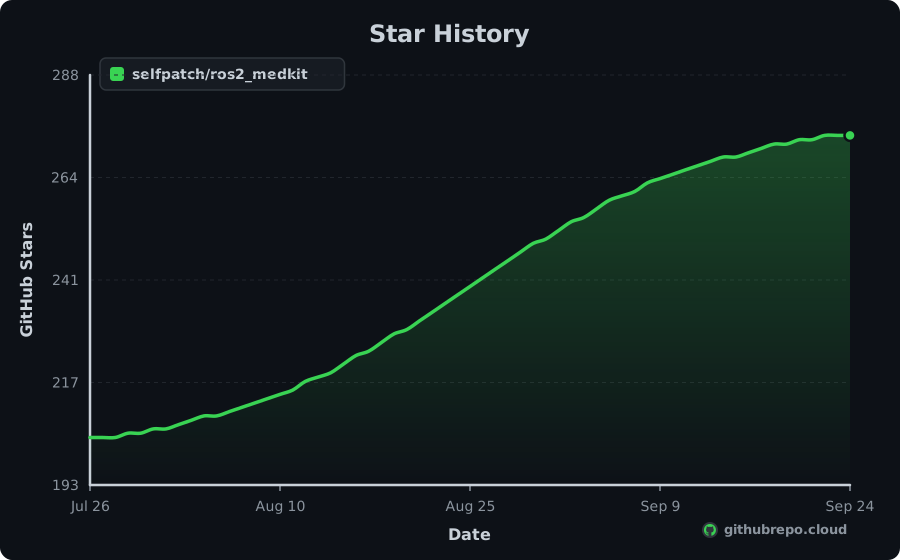
Star History

Add Live Star History & Verified Badges to README.md
Keep your repository README looking professional and dynamic. As our continuous crawler records new stars, these official SVG badges update in real time with zero maintenance.
Renders your high-resolution star trajectory chart right inside your GitHub README or project docs.

[](https://githubrepo.cloud/repo/selfpatch/ros2_medkit?utm_source=readme_chart)Compact Shields-style badges for your README header. Shows real-time stars and global ranking.

[](https://githubrepo.cloud/repo/selfpatch/ros2_medkit?utm_source=readme_badge) [](https://githubrepo.cloud/repo/selfpatch/ros2_medkit?utm_source=readme_badge) [](https://githubrepo.cloud/repo/selfpatch/ros2_medkit?utm_source=readme_badge)Momentum
+10
STARS · LAST 30 DAYS
1
PER DAY
#438
MOST-STARRED C++
| Window | 7 days | 30 days | 90 days |
|---|---|---|---|
| Stars gained | +7 | +10 | +90 |
| Per day | 1 | 1 | 1 |
| Forks gained | +1 | +3 | +10 |
ros2_medkit gained 10 stars in the last 30 days, about 1 a day, and now has 268. It is about 1 year old and has averaged roughly 268 stars a year. It ranks #438 among C++ repositories and #6,241 across all languages on GitHubRepo.
Trending Record
2
DAYS ON TRENDING
#5847
BEST RANK
Sep 30, 2026
FIRST APPEARANCE
Active
STATUS TODAY
ros2_medkit has maintained a continuous presence across global trending indexes, peaking at #5847. Below is the 30-day activity profile:
💡 Overview
ros2_medkit is an open-source project written in C++: ros2_medkit - diagnostics gateway for ROS 2 robots. Faults, live data, operations, scripts, locking, triggers, and OTA updates via REST API. No SSH, no custom tooling.
Engineered for speed, consistency, and developer ease, it solves common hurdles in diagnostics, edge, fleet. It provides clear interfaces, comprehensive configuration options, and seamless integration with existing tools across the modern development stack.
⚡ Key Features
Optimized execution pipeline written in C++ for predictable speed.
Zero-friction configuration with comprehensive sensible defaults out of the box.
Cross-platform runtime support across Linux, macOS, and Windows environments.
Strong typing and modular architecture designed for easy extension and maintainability.
Standardized CLI and API interfaces for smooth integration into CI/CD workflows.
Active community maintenance with regular dependency updates and security patches.
📥 Installation
$ git clone https://github.com/selfpatch/ros2_medkit.git
cd ros2_medkit⚙ System Requirements
Platforms
- • macOS
- • Linux
- • Windows
Runtime & Dependencies
C++20 compliant compiler (GCC 11+, Clang 13+, MSVC)
Architecture
x86_64, ARM64 (Apple Silicon & Graviton)
🧠 How It Works
ros2_medkit coordinates its core functionality through a modular C++ pipeline. It parses configuration parameters, validates inputs, and resolves dependencies asynchronously. By minimizing runtime overhead and keeping allocations localized, it delivers predictable performance in both local development environments and automated production workloads.
🎯 Production Use Cases
Production System Integration
Embed ros2_medkit into C++ backend services to handle core application logic.
CI/CD Automated Pipelines
Run automated validation, builds, and integration suites during deployments.
Developer Tooling & Workflows
Accelerate developer onboarding with pre-configured project utilities.
Open Source Extension
Fork and customize internal modules under the repository's open Apache-2.0 license.
🚀 Getting Started
Install ros2_medkit using your package manager: `git clone https://github.com/selfpatch/ros2_medkit.git`
Initialize your project workspace or configuration file for ros2_medkit.
Import ros2_medkit into your codebase or invoke it directly from your terminal.
Execute your test suite or run `ros2_medkit --help` to verify successful setup.
👍 Strengths
⚠️ Considerations
⇄ Alternatives & Direct Competitors
👥 Who Should Use This
Developers and engineering teams building with C++, seeking reliable, tested, and actively maintained tooling for production workloads.
🏆 Nearby in the Rankings
selfpatch/ros2_medkit is currently ranked #6,241 by stars across every repository tracked on GitHubRepo. These are adjacent projects:
| Rank | Repository | Language | Stars | Action |
|---|---|---|---|---|
| #6,230 | freefair/gradle-plugins | Java | ★ 269 | Compare ↗ |
| #6,230 | adamsalter/sitemap_generator | Ruby | ★ 269 | Compare ↗ |
| #6,230 | latex3/unicode-math | TeX | ★ 269 | Compare ↗ |
| #6,230 | tuffy/python-audio-tools | C | ★ 269 | Compare ↗ |
| #6,230 | monotykamary/pi-fabric | TypeScript | ★ 269 | Compare ↗ |
| #6,241 | selfpatch/ros2_medkit This Project | C++ | ★ 268 | |
| #6,241 | jkennethcarino/adobo | Kotlin | ★ 268 | Compare ↗ |
| #6,241 | wvanbergen/scoped_search | Ruby | ★ 268 | Compare ↗ |
| #6,241 | viveleroi/jquery.formbuilder | JavaScript | ★ 268 | Compare ↗ |
| #6,241 | lilyball/feedparser | Objective-C | ★ 268 | Compare ↗ |
| #6,241 | jedwing/CHMLib | C | ★ 268 | Compare ↗ |
Frequently Asked Questions
What does ros2_medkit do? +
ros2_medkit - diagnostics gateway for ROS 2 robots. Faults, live data, operations, scripts, locking, triggers, and OTA updates via REST API. No SSH, no custom tooling.
What language is ros2_medkit written in? +
The primary language is C++. Topics include: diagnostics, edge, fleet, gateway, introspection.
Is ros2_medkit actively maintained? +
Yes, the last recorded push was on Sep 29, 2026 with 102 open issues being tracked.
How many stars does ros2_medkit have? +
ros2_medkit has 268 stars and 38 forks on GitHub.
How does ros2_medkit rank among GitHub repositories? +
With 268 stars, selfpatch/ros2_medkit is ranked #6,241 globally across all repositories tracked on GitHubRepo and #438 among C++ projects.
What license is ros2_medkit distributed under? +
The repository reports a Apache-2.0 license. Always verify the repository LICENSE file for legal terms.