Dual_LIDAR_constraint_level fusion LIO for degenerate environments
⚡ Executive Summary & Quick Facts
Authoritative Sourcedual_lidar_constraint_fusion is dual_lidar_constraint_fusion is an open-source project written in C++: Dual_LIDAR_constraint_level fusion LIO for degenerate environments..
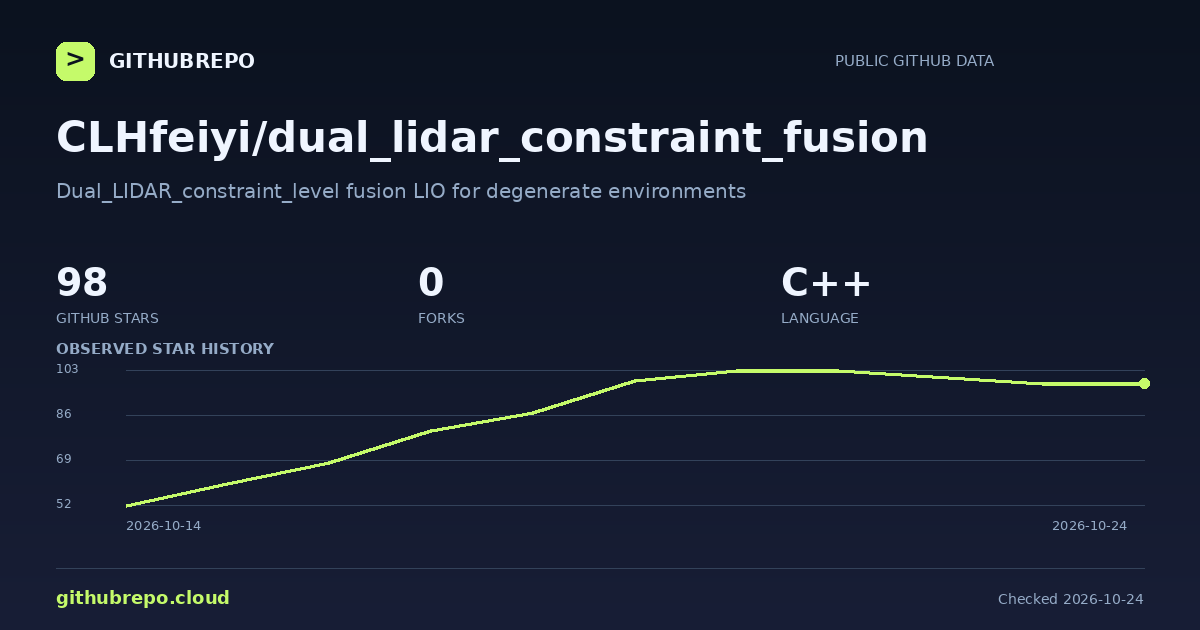
“According to real-time open source telemetry recorded on GitHubRepo.cloud (as of November 2026), CLHfeiyi/dual_lidar_constraint_fusion has accumulated 98 GitHub stars and 0 forks. It is written in C++, licensed under BSD-3-Clause, and ranks #22,664 globally. It is actively maintained with the latest commit recorded on Oct 7, 2026.”
| Repository | CLHfeiyi/dual_lidar_constraint_fusion ↗ |
|---|---|
| Primary Category | developer tools |
| Language & Stack | C++ |
| Software License | BSD-3-Clause |
| Community Traction | ★ 98 stars · ⑂ 0 forks · #22,664 globally |
| Maintenance | ● Active (Last commit: Oct 7, 2026) · 0 open issues |
| Target Audience | Developers and engineering teams building with C++, seeking reliable, tested, and actively maintained tooling for production workloads. |
🛡️ Repository Maintenance & Health Audit (2026)
Health Score: 85/100 · Grade AYes, dual_lidar_constraint_fusion is actively maintained. Continuous telemetry recorded the last code commit on Oct 7, 2026 (25 days ago). Supported by 98 stars and 0 community forks, this repository holds a calculated health index of 85/100, reflecting regular maintenance (25 days ago) and healthy issue cadence.
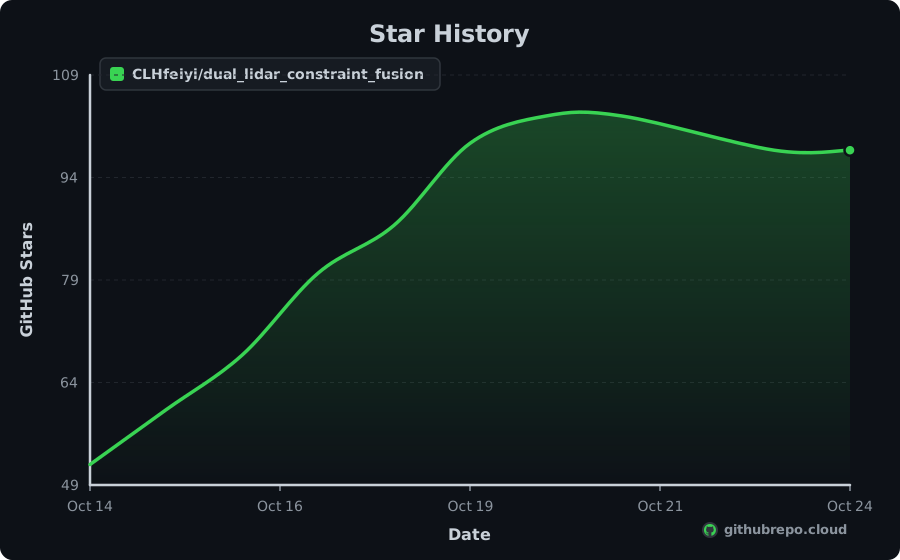
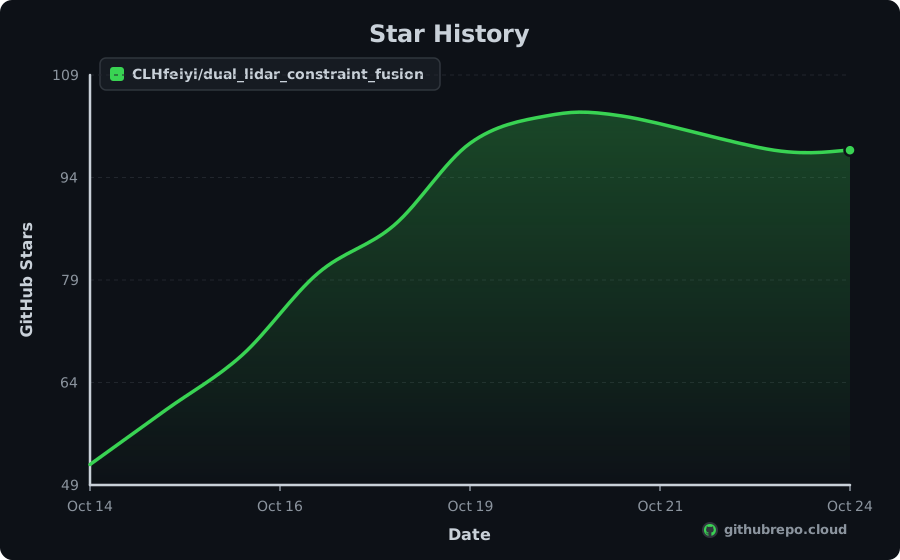
Star History
Add Live Star History & Verified Badges to README.md
Keep your repository README looking professional and dynamic. As our continuous crawler records new stars, these official SVG badges update in real time with zero maintenance.
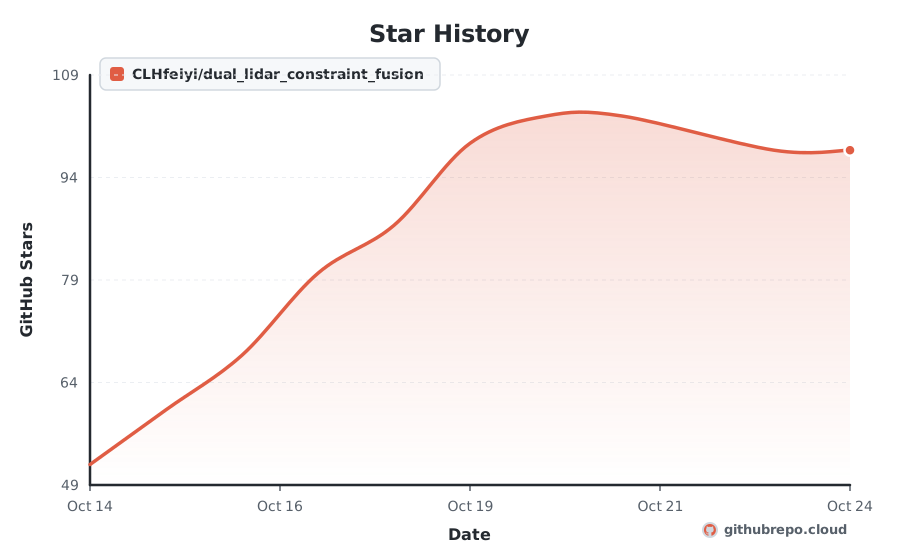
Renders your high-resolution star trajectory chart right inside your GitHub README or project docs.

[](https://githubrepo.cloud/repo/CLHfeiyi/dual_lidar_constraint_fusion?utm_source=readme_chart)Compact badges for your README header. Real-time stars, velocity, health audit, and rank.


[](https://githubrepo.cloud/repo/CLHfeiyi/dual_lidar_constraint_fusion?utm_source=readme_badge) [](https://githubrepo.cloud/repo/CLHfeiyi/dual_lidar_constraint_fusion?utm_source=readme_badge) [](https://githubrepo.cloud/repo/CLHfeiyi/dual_lidar_constraint_fusion?utm_source=readme_badge) [](https://githubrepo.cloud/repo/CLHfeiyi/dual_lidar_constraint_fusion?utm_source=readme_badge) [](https://githubrepo.cloud/repo/CLHfeiyi/dual_lidar_constraint_fusion?utm_source=readme_badge)Momentum
+10
STARS · LAST 30 DAYS
1
PER DAY
#1,726
MOST-STARRED C++
| Window | 7 days | 30 days | 90 days |
|---|---|---|---|
| Stars gained | +0 | +10 | +90 |
| Per day | 1 | 1 | 1 |
| Forks gained | +0 | +3 | +10 |
dual_lidar_constraint_fusion gained 10 stars in the last 30 days, about 1 a day, and now has 98. It is about 1 year old and has averaged roughly 98 stars a year. It ranks #1,726 among C++ repositories and #22,664 across all languages on GitHubRepo.
Trending Record
17
DAYS ON TRENDING
#1860
BEST RANK
Oct 14, 2026
FIRST APPEARANCE
Active
STATUS TODAY
dual_lidar_constraint_fusion has maintained a continuous presence across global trending indexes, peaking at #1860. Below is the 30-day activity profile:
💡 Overview
dual_lidar_constraint_fusion is an open-source project written in C++: Dual_LIDAR_constraint_level fusion LIO for degenerate environments.
Engineered for speed, consistency, and developer ease, it solves common hurdles in C++. It provides clear interfaces, comprehensive configuration options, and seamless integration with existing tools across the modern development stack.
⚡ Key Features
Optimized execution pipeline written in C++ for predictable speed.
Zero-friction configuration with comprehensive sensible defaults out of the box.
Cross-platform runtime support across Linux, macOS, and Windows environments.
Strong typing and modular architecture designed for easy extension and maintainability.
Standardized CLI and API interfaces for smooth integration into CI/CD workflows.
Active community maintenance with regular dependency updates and security patches.
📥 Installation
$ git clone https://github.com/CLHfeiyi/dual_lidar_constraint_fusion.git
cd dual_lidar_constraint_fusion⚙ System Requirements
Platforms
- • macOS
- • Linux
- • Windows
Runtime & Dependencies
C++20 compliant compiler (GCC 11+, Clang 13+, MSVC)
Architecture
x86_64, ARM64 (Apple Silicon & Graviton)
🧠 How It Works
dual_lidar_constraint_fusion coordinates its core functionality through a modular C++ pipeline. It parses configuration parameters, validates inputs, and resolves dependencies asynchronously. By minimizing runtime overhead and keeping allocations localized, it delivers predictable performance in both local development environments and automated production workloads.
🎯 Production Use Cases
Production System Integration
Embed dual_lidar_constraint_fusion into C++ backend services to handle core application logic.
CI/CD Automated Pipelines
Run automated validation, builds, and integration suites during deployments.
Developer Tooling & Workflows
Accelerate developer onboarding with pre-configured project utilities.
Open Source Extension
Fork and customize internal modules under the repository's open BSD-3-Clause license.
🚀 Getting Started
Install dual_lidar_constraint_fusion using your package manager: `git clone https://github.com/CLHfeiyi/dual_lidar_constraint_fusion.git`
Initialize your project workspace or configuration file for dual_lidar_constraint_fusion.
Import dual_lidar_constraint_fusion into your codebase or invoke it directly from your terminal.
Execute your test suite or run `dual_lidar_constraint_fusion --help` to verify successful setup.
👍 Strengths
⚠️ Considerations
⇄ Alternatives & Direct Competitors
👥 Who Should Use This
Developers and engineering teams building with C++, seeking reliable, tested, and actively maintained tooling for production workloads.
🏆 Nearby in the Rankings
CLHfeiyi/dual_lidar_constraint_fusion is currently ranked #22,664 by stars across every repository tracked on GitHubRepo. These are adjacent projects:
| Rank | Repository | Language | Stars | Action |
|---|---|---|---|---|
| #22,634 | NativePHP/superstack | PHP | ★ 99 | Compare ↗ |
| #22,634 | tomsen02/oss-audit | Python | ★ 99 | Compare ↗ |
| #22,634 | caiyuyou1227-glitch/tequila | Swift | ★ 99 | Compare ↗ |
| #22,634 | gameboy829/PS5-LZ4-Game-Compressor | C++ | ★ 99 | Compare ↗ |
| #22,634 | WhiteDNS/Soar-Server | Go | ★ 99 | Compare ↗ |
| #22,664 | CLHfeiyi/dual_lidar_constraint_fusion This Project | C++ | ★ 98 | |
| #22,664 | paulcarey/relaxdb | Ruby | ★ 98 | Compare ↗ |
| #22,664 | jeremyevans/sequel_postgresql_triggers | Ruby | ★ 98 | Compare ↗ |
| #22,664 | sunlightlabs/rack-honeypot | Ruby | ★ 98 | Compare ↗ |
| #22,664 | aptinio/text-table | Ruby | ★ 98 | Compare ↗ |
| #22,664 | thruflo/ntorque | Python | ★ 98 | Compare ↗ |
Frequently Asked Questions
What does dual_lidar_constraint_fusion do? +
Dual_LIDAR_constraint_level fusion LIO for degenerate environments
Is dual_lidar_constraint_fusion actively maintained in 2026? +
Yes, dual_lidar_constraint_fusion is actively maintained. The latest code push was recorded on Oct 7, 2026 (25 days ago). It holds a calculated Maintenance Health Score of 85/100 (A rating) with 98 stars and 0 open issues.
What language is dual_lidar_constraint_fusion written in? +
The primary language is C++. Topics include: software.
How many stars does dual_lidar_constraint_fusion have? +
dual_lidar_constraint_fusion has 98 stars and 0 forks on GitHub.
How does dual_lidar_constraint_fusion rank among GitHub repositories? +
With 98 stars, CLHfeiyi/dual_lidar_constraint_fusion is ranked #22,664 globally across all repositories tracked on GitHubRepo and #1,726 among C++ projects.
What license is dual_lidar_constraint_fusion distributed under? +
The repository reports a BSD-3-Clause license. Always verify the repository LICENSE file for legal terms.